Custom hexapod robot with blue and white 3D-printed legs on a workbench
Madhav Malpani · AI × Robotics × Hardware

Building robots that extend human capability.

One iteration at a time.

I’m an undergraduate Artificial Intelligence student at UC San Diego. I build physical systems — legged robots, embedded hardware and prototypes — and learn by taking them apart and improving them.

NowTriton Robotics — CAN FD transceiver board
FocusComputer Vision · VLA models · Reinforcement Learning
San Diego--:--:-- PT
Scroll
01 — Why robotics

Robots should extend what people can do.

Focus

Practical systems

My work lives at the intersection of mechanical design, electronics, embedded systems, and intelligent control.

Applications

Real work

I care about warehouse automation, search and rescue, ocean exploration, household automation, and industrial systems.

How I work↻ repeat
  1. 01UnderstandTake the system apart — mechanics, electronics, control.
  2. 02PrototypeBuild a physical version, however rough.
  3. 03ExperimentRun it, measure it, find where it breaks.
  4. 04IterateFix, rebuild, and go around again.
Engineering interests06 topics
  • 01Computer Vision
  • 02Vision-Language-Action Models
  • 03Consumer Robotics
  • 04Custom Motors for Robot Joints
  • 05Tesla Full Self-Driving Chips
  • 06Reinforcement Learning
02 — Selected work

Systems I’ve built and explored.

Legged robots, space hardware, embedded sensing and physical prototypes — hands-on builds at every stage, from first assembly to completed prototype.

Robotics02 flagship builds
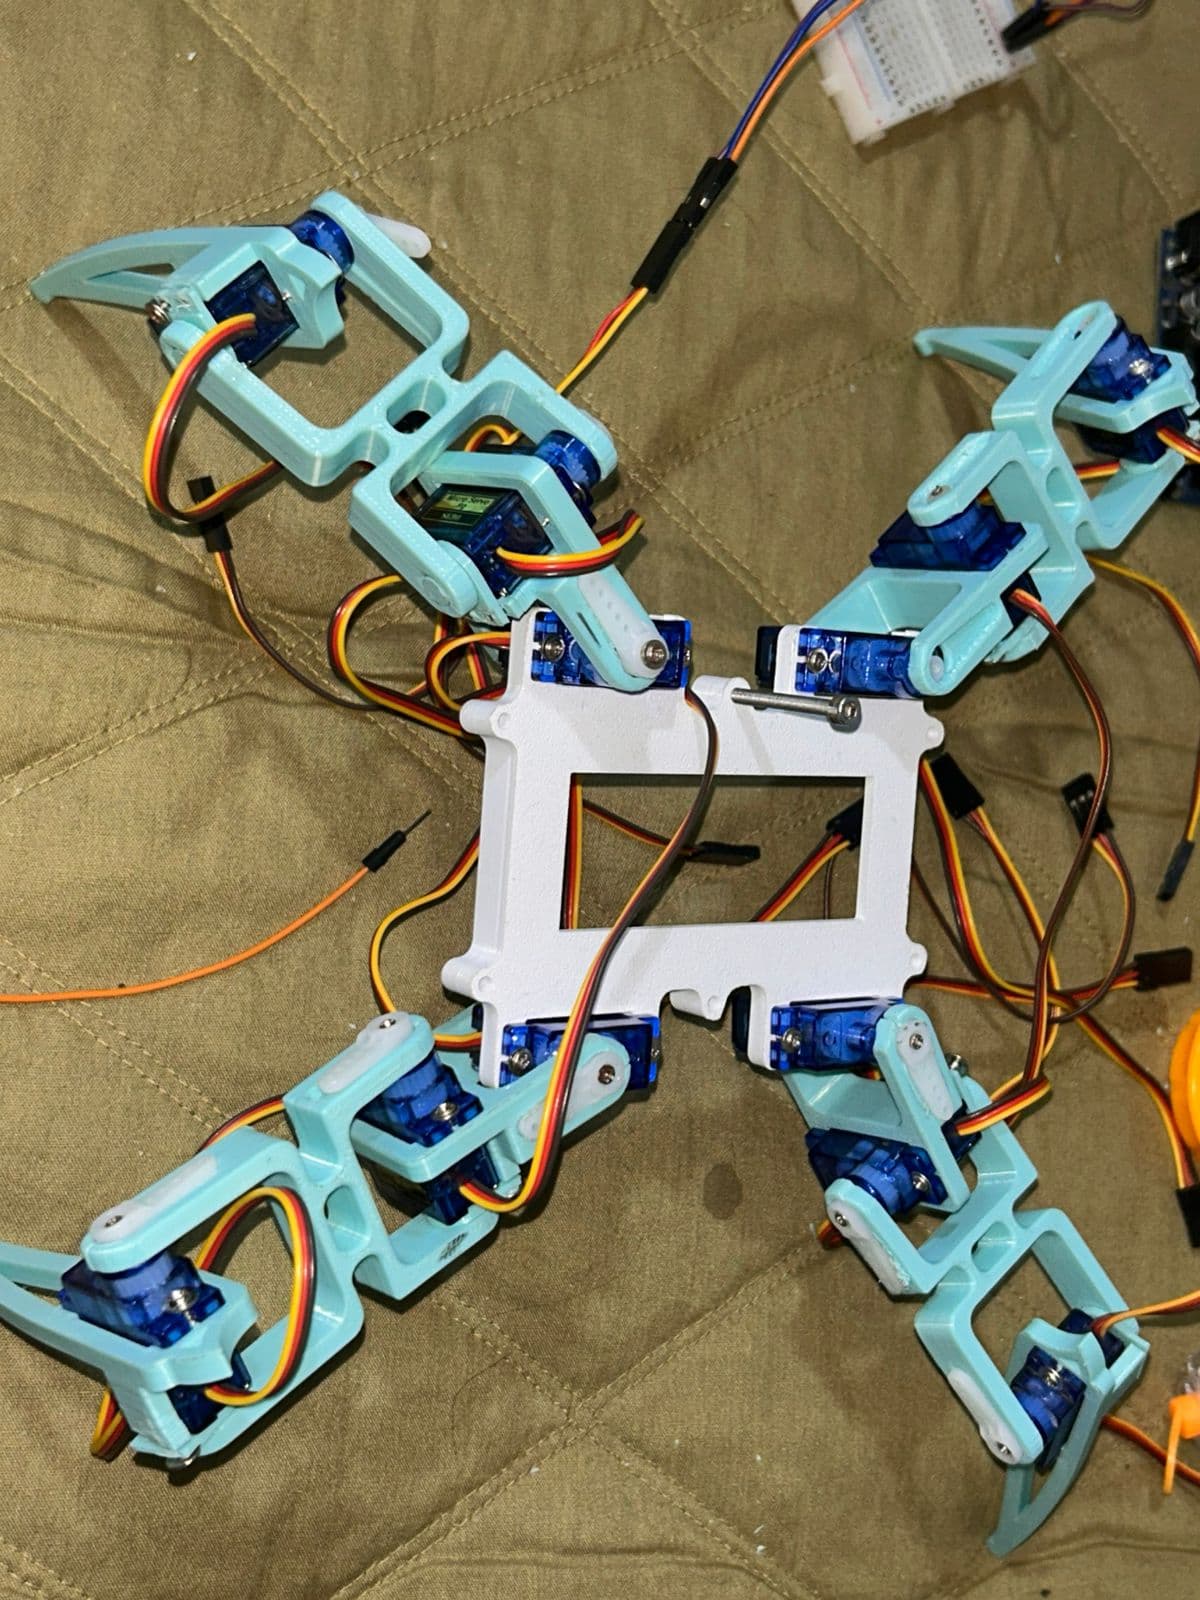
FIG. 01.1The assembled four-leg platform
01IN PROGRESS
Robotics / Kinematics

Quadruped Leg Kinematics

I assembled an open-source quadruped platform with four 3-DOF legs, developed an object-oriented Python kinematics framework, and built a physics simulation of the robot from its own 3D-printed part files that walks, turns, and jumps in MuJoCo.

01
4 x 3-DOF leg design
02
Forward and inverse kinematics framework
03
Joint-angle and end-effector coordinate control
04
Workspace visualization
05
MuJoCo simulation built from the printed STL parts, validated against the FK model
06
Statically stable crawl gait walking in simulation
07
In-place turning at about 14°/s with tank-steer leg control
08
Crouch-and-thrust jump: about 11 cm of liftoff, lands upright

Kinematics framework developed / physical platform assembled / walking, turning and jumping in MuJoCo simulation / hardware locomotion in progress.
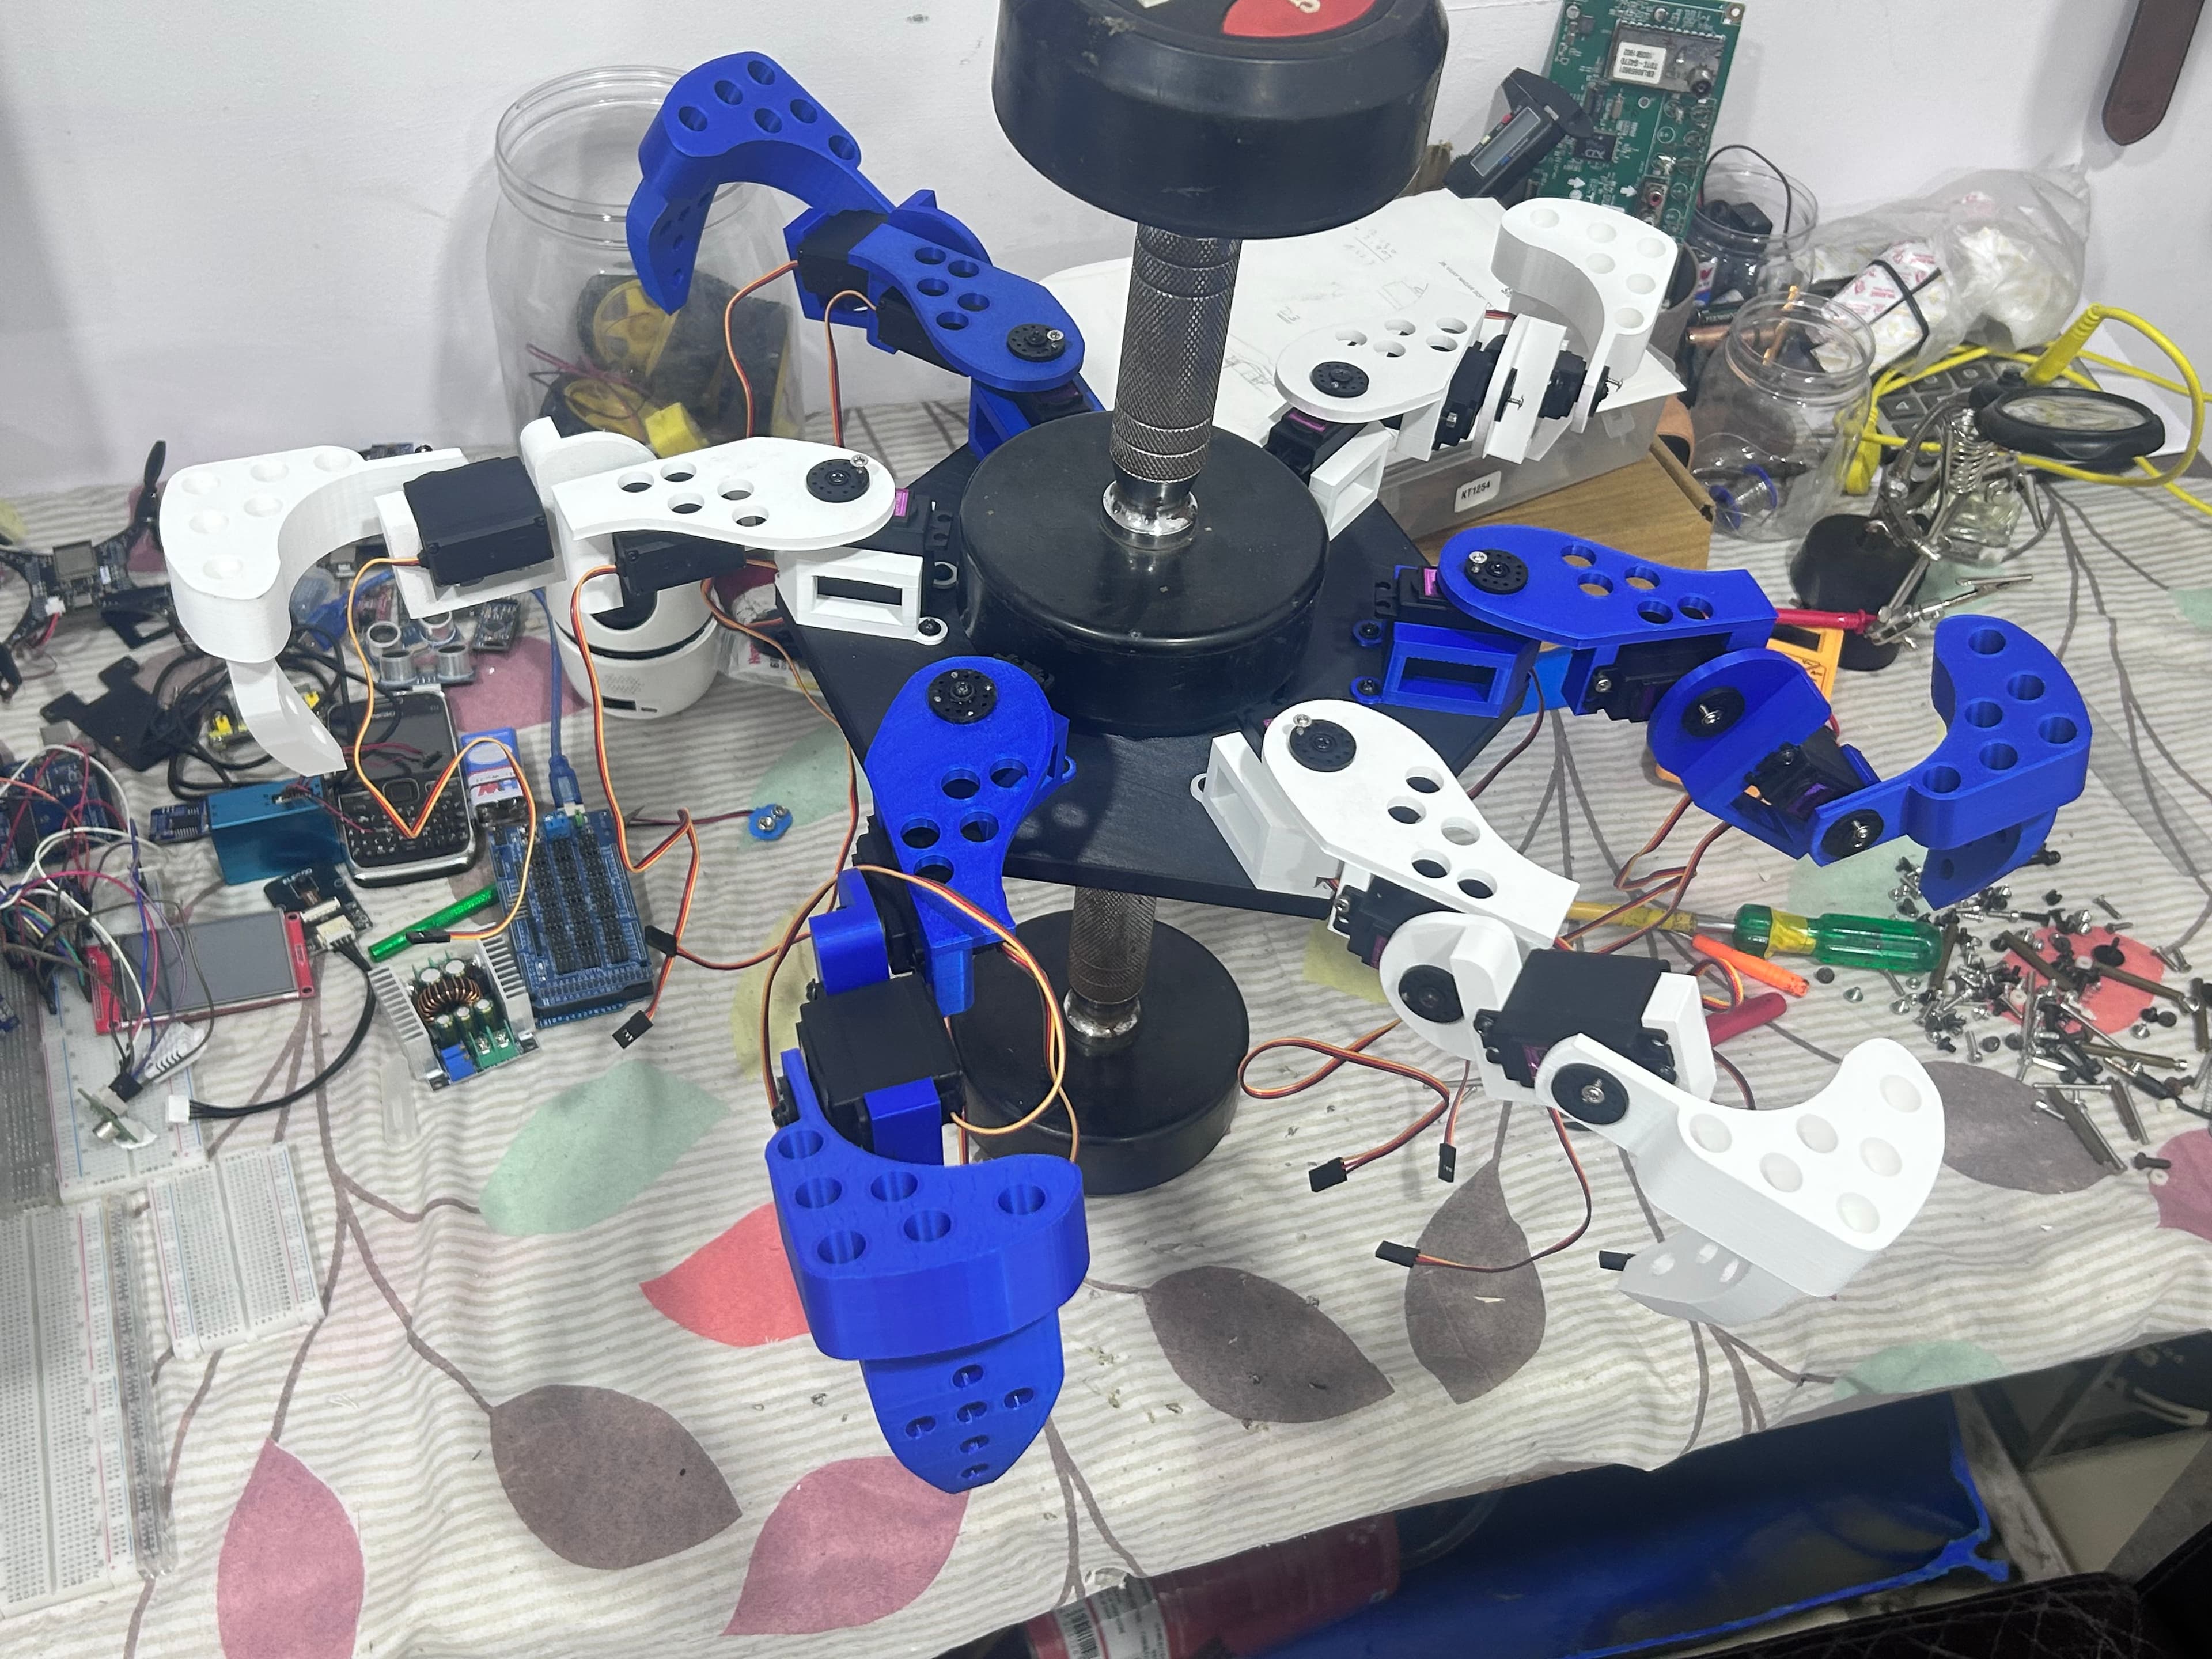
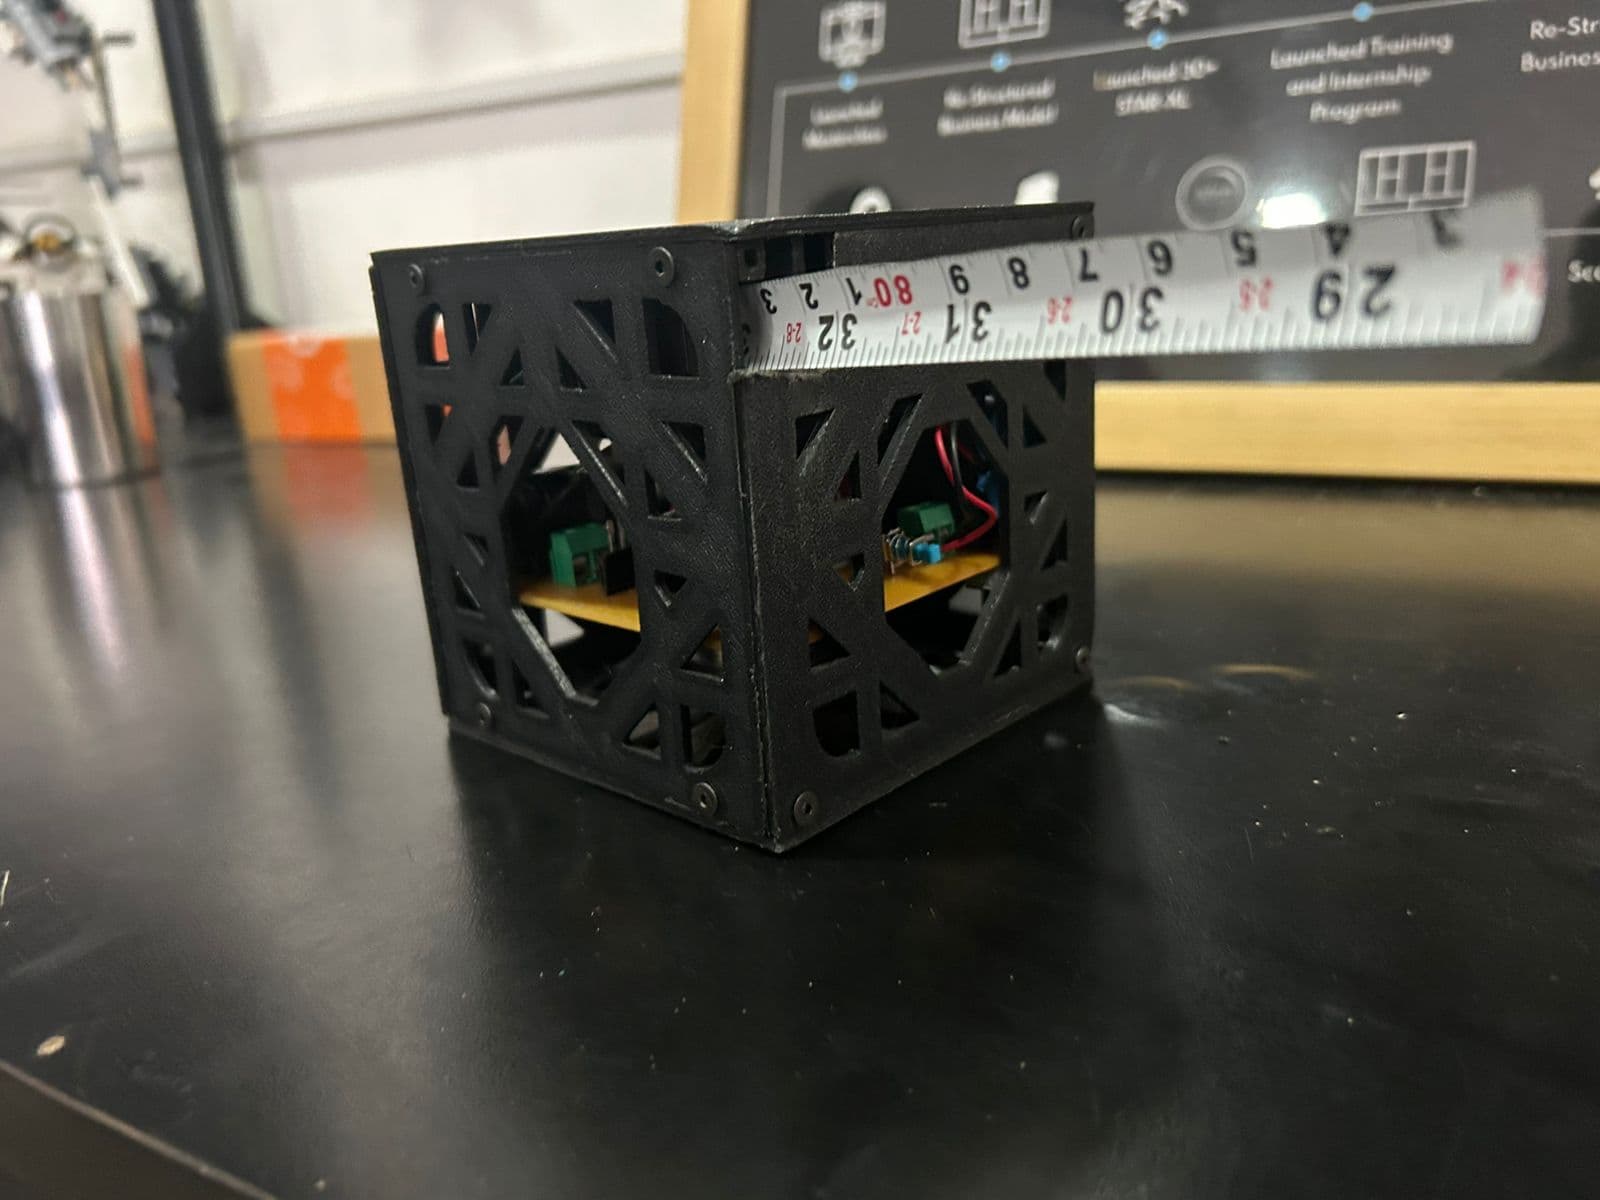
FIG. 02.1Full assembled Hexapod
02IN PROGRESS
Robotics / Mechanical Systems

Custom Hexapod

A custom-built, approximately 70 cm wide hexapod with 18 MG996R servos, an Arduino Mega, and over 20 3D-printed parts.

01
Approx. 70 cm wide robot body
02
18 MG996R servos
03
20+ 3D-printed parts
04
Mechanical assembly complete

Mechanical assembly complete / locomotion development ongoing.

Hardware & prototypes03 projects
Software & hackathons02 projects
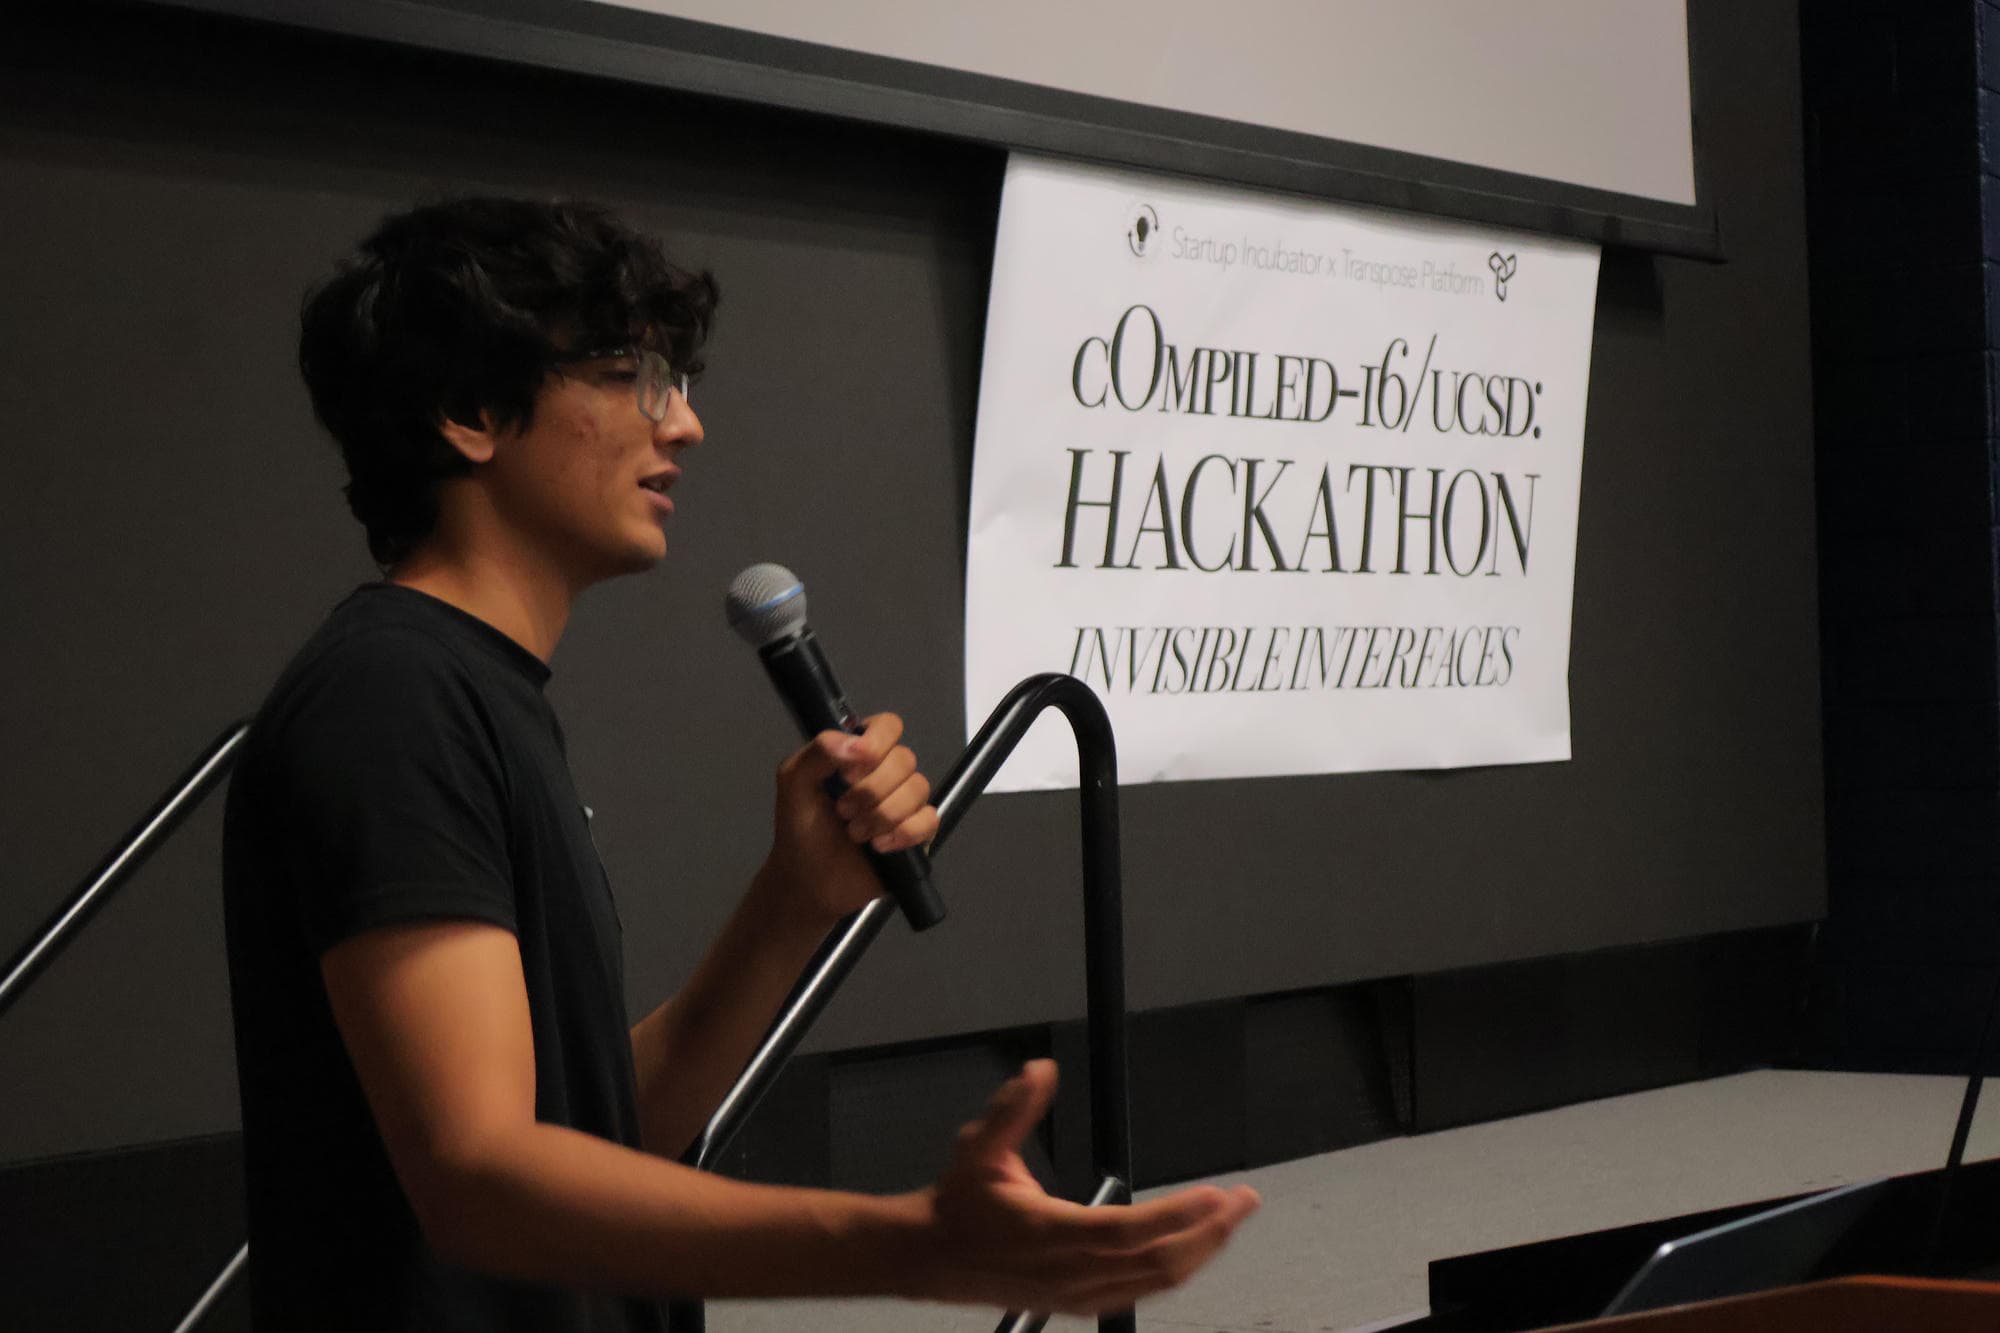
Top 7441 participants · 200+ teamscOmpiled-16 UCSD Hackathon
Hackathon / LogisticsPROTOTYPE

BorderPulse

A logistics platform concept for dispatchers and receivers that helps evaluate border-crossing conditions, identify delays, and make rerouting decisions.

03 — Experience

Where I’ve been building.

Robotics teams, internships, training programs and community work — newest first.

CURRENTLY BUILDINGAug 2026 – Present

Triton Robotics

Electronics Sub-Team Recruit · UC San Diego

Working on the legacy center-board design by reviewing power and signal distribution, modifying the PCB during week 2, and building a LM555 timer circuit on a general-purpose board during training. For the capstone, I am designing and building a CAN FD transceiver breakout board, with PCB Version 1 followed by PCB Version 3.

  • Reviewed an older center-board design for power and signal distribution
  • Modified the center-board PCB during week 2 of training
  • Built an LM555 timer circuit on a general-purpose board during week 1 and week 3 training
  • Designing and building a CAN FD transceiver breakout board as the capstone project
  • Developed PCB Version 1 and PCB Version 3 in chronological order
Iteration log
  1. LM555LM555 timer prototype
  2. DemoLM555 timer demonstration
  3. PCB V1Initial PCB layout — bottom-layer copper
  4. PCB V3Final PCB layout — top-layer copper
  1. Jun 2025 – Jul 2025

    Mechanical Design & Fabrication Intern

    Space Technology / Aeronautical Rocketry startup

    • 3D-printed CubeSat model work
    • Antenna deployment mechanism design and testing support
    • Assembly and soldering support
  2. Jan 2025 – Feb 2025

    Machine Learning Intern

    IIT Kanpur / Techkriti

    • Fundamental machine learning and linear algebra study
    • SVM-based handwritten digit classifier using Python and scikit-learn
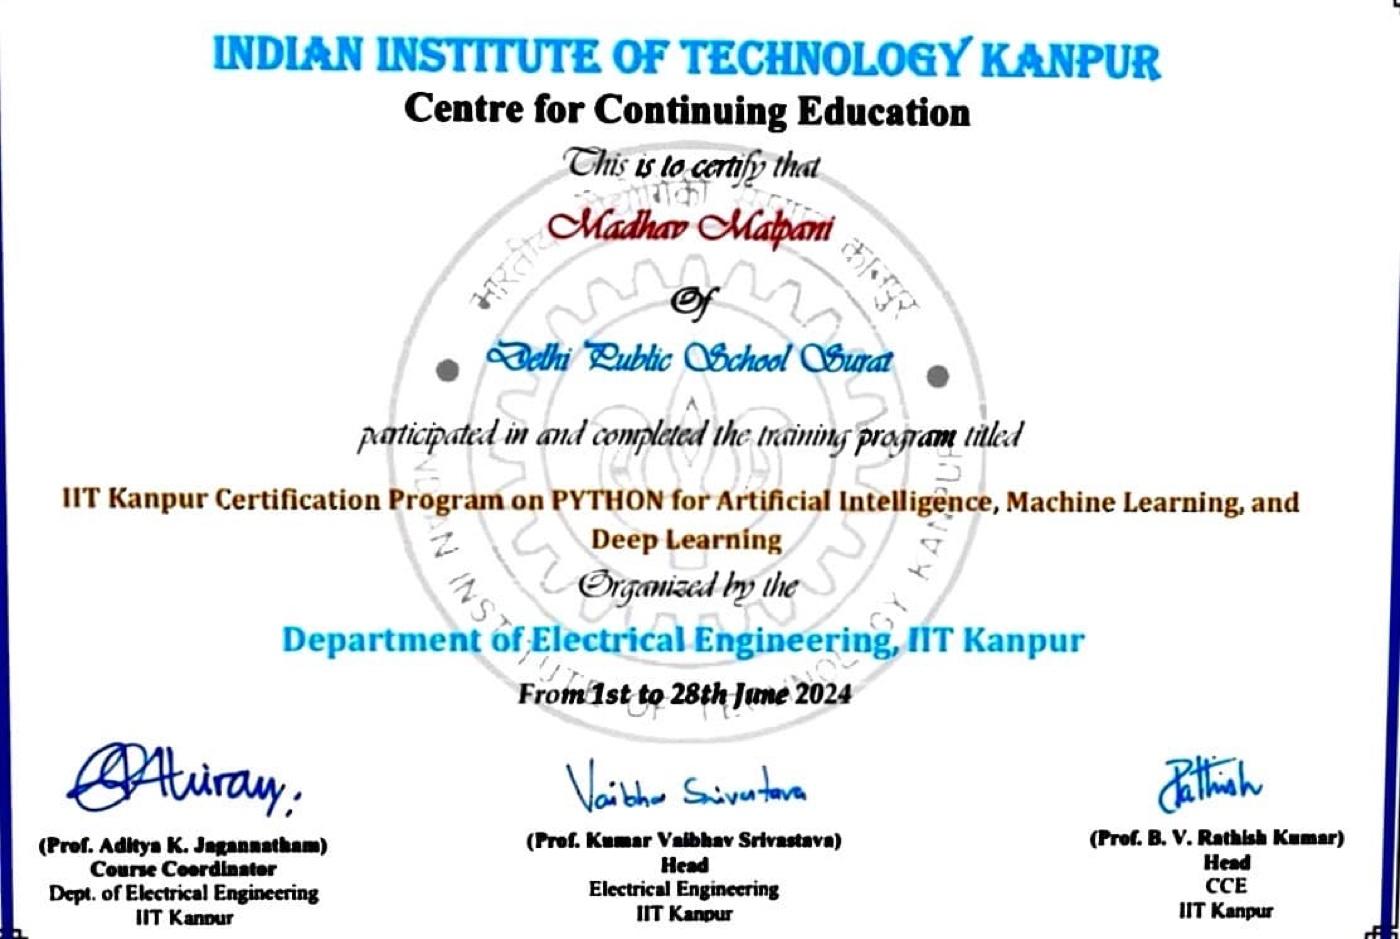
    • Completed the IIT Kanpur Certification Program on Python for Artificial Intelligence, Machine Learning, and Deep Learning, organized by the Department of Electrical Engineering (1–28 June 2024)
    IIT Kanpur certificate for the Certification Program on Python for Artificial Intelligence, Machine Learning, and Deep Learning
    Python for AI, ML & Deep Learning certificate
  3. May 2024 – Jan 2026

    Event Organiser

    Pickle It Down

    Pickle It Down on Instagram
    • Co-founded a pickleball community that brought together 50+ players for tournaments and social events
    • Managed venue booking, logistics, catering, and match-fixture planning
    • Built and grew an Instagram community to promote events and keep players engaged — ~8,000 profile visits a month and 51,781+ views on reels
    • Earned ~₹50,000 (INR) in revenue
    • Organised get-togethers and social sessions so players could meet new people and play together
    • Motto: “We connect, you play.”
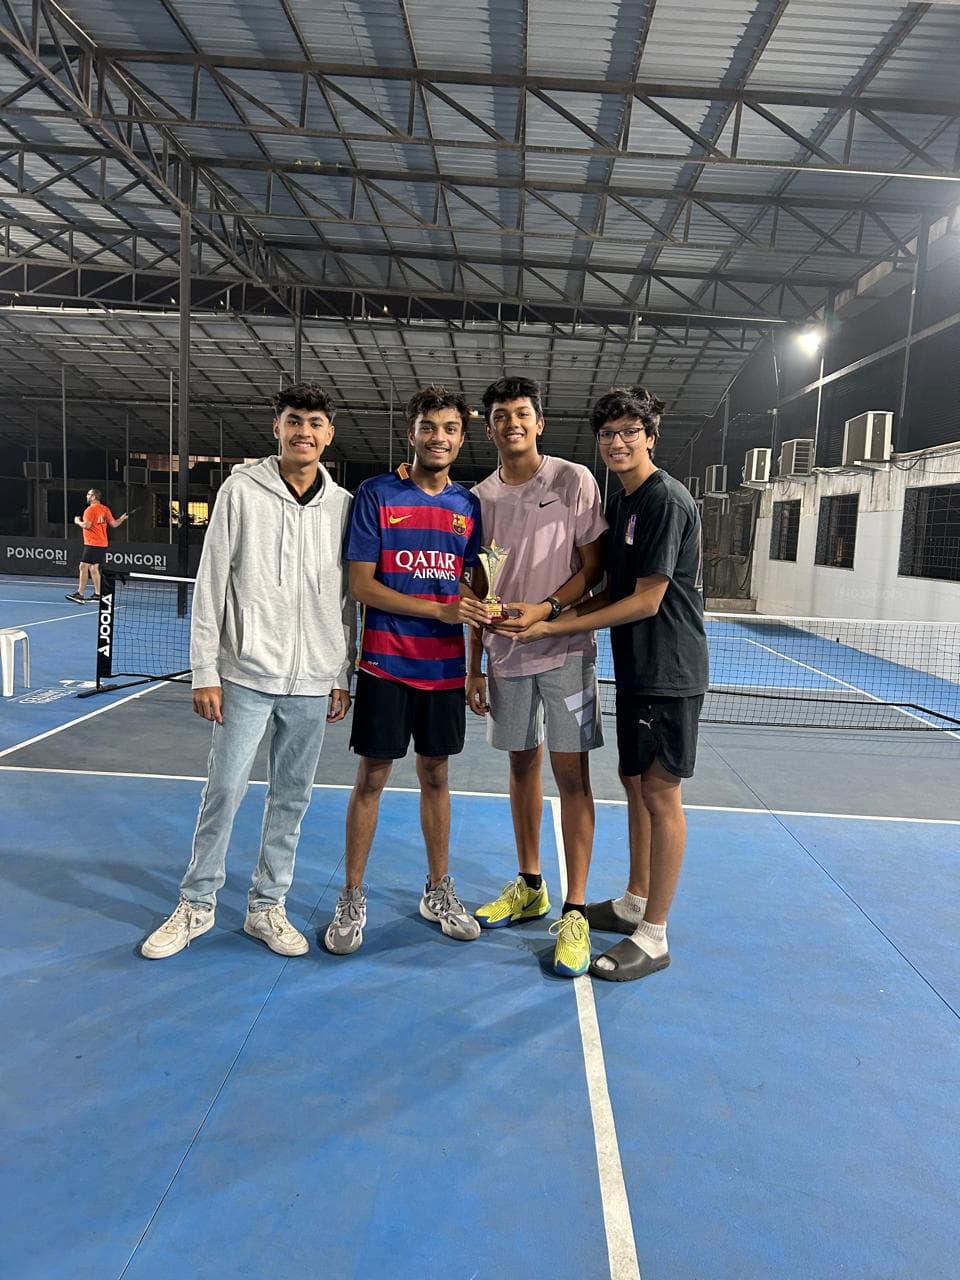
    Pickle It Down tournament winners on the court
    Pickle It Down tournament
Education
Expected June 2030

University of California San Diego

B.S. Artificial Intelligence

2011–2026

Delhi Public School, Surat

Central Board of Secondary Education (CBSE)

  • Senior secondary subjects: Mathematics, Physics, Chemistry, English, and Computer Science
  • Scored 93 in Computer Science and 89 in Mathematics
  • Captain of the school basketball team (2026)
  • Student Council House Captain — one of only 4 selected out of 200
  • Represented Dragon House (1,000+ students)
04 — Toolkit & recognition

Tools I use. Results so far.

The languages, hardware skills and software I actually work with, plus competition results.

S.1

Programming

05
  • Python
  • Java
  • TypeScript
  • C/C++
  • MySQL
S.2

Engineering

06
  • Embedded Systems
  • PCB Design
  • CAD
  • Soldering
  • IoT Systems
  • Vibe Coding
S.3

Software & tools

06
  • Onshape
  • GitHub
  • EasyEDA
  • CST Studio
  • Claude Code
  • Codex
Awards04
  1. 2025International Computer Science Competition FinalistTop 500of 10,000 participants
  2. 2025Mental Math World Cup#411of 8600 globally
  3. 2025Aryabhatta National Math Competition#639of 10,000 nationally
  4. 2024Ramanujan National Math Competition#373of 6,000 nationally
Also explored02
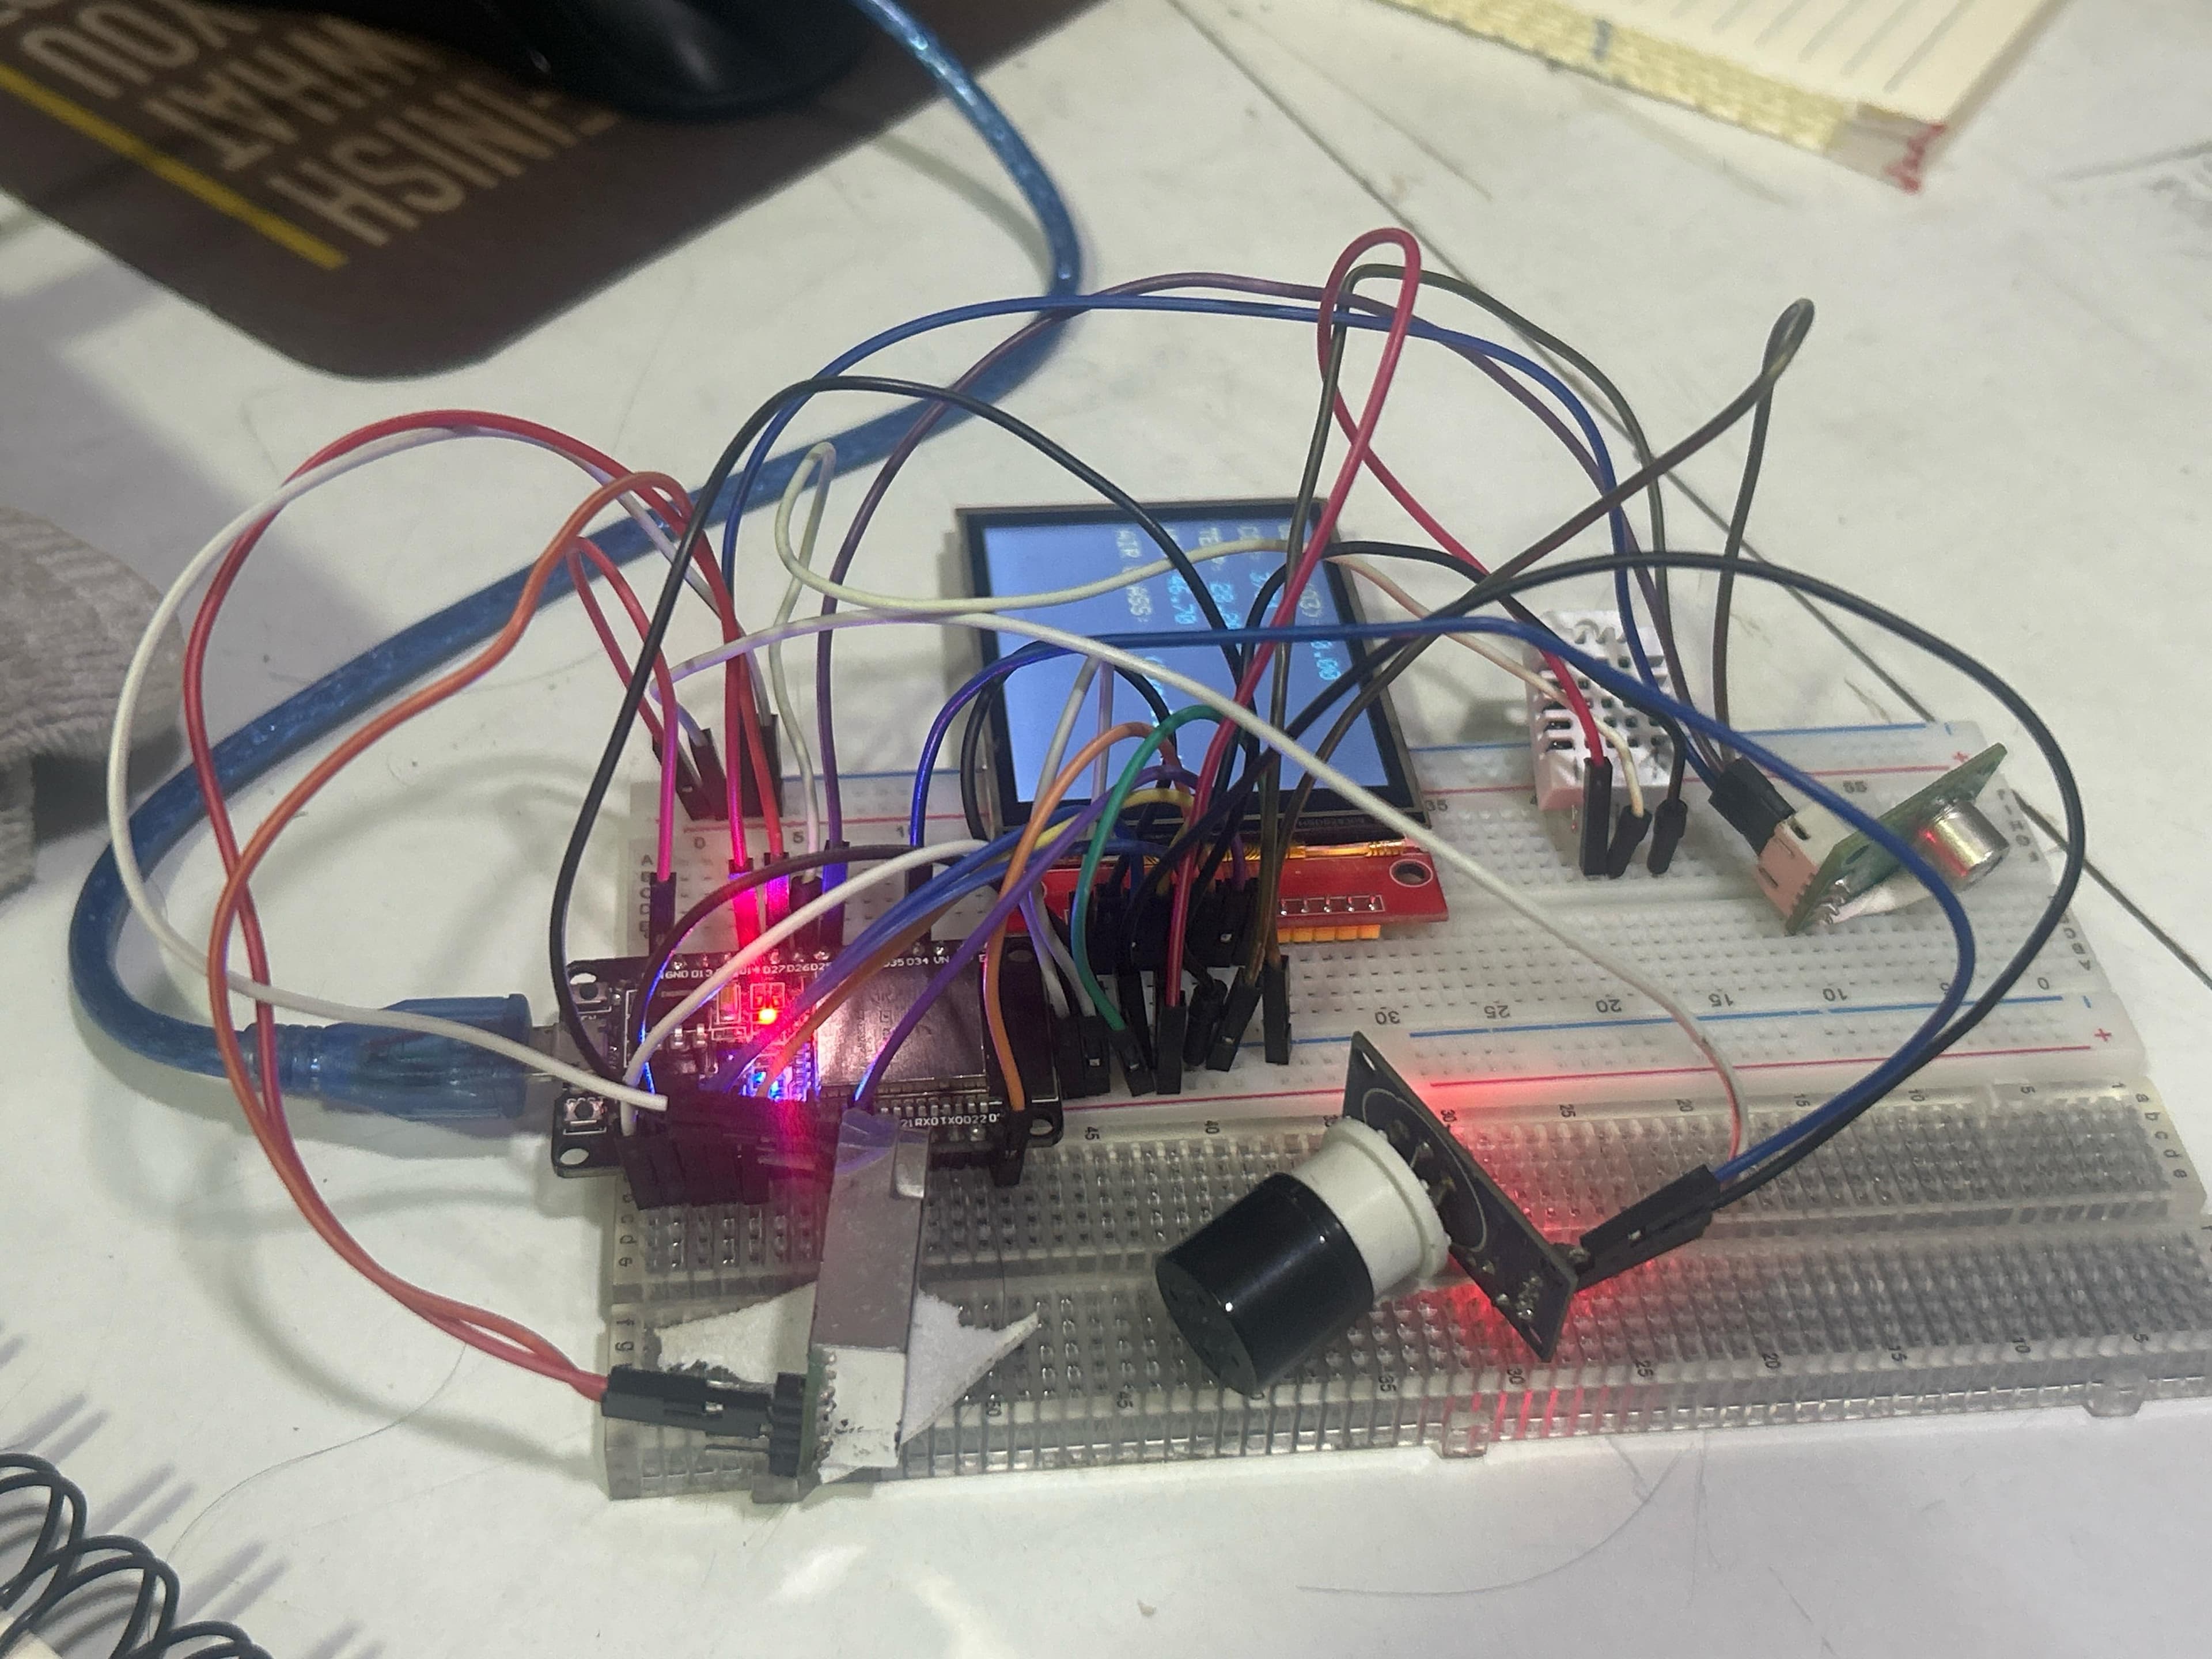
  • Gesture-Controlled DroneESP32 board soldering · 3D-printed components · CAD work · Project was not successfully completed
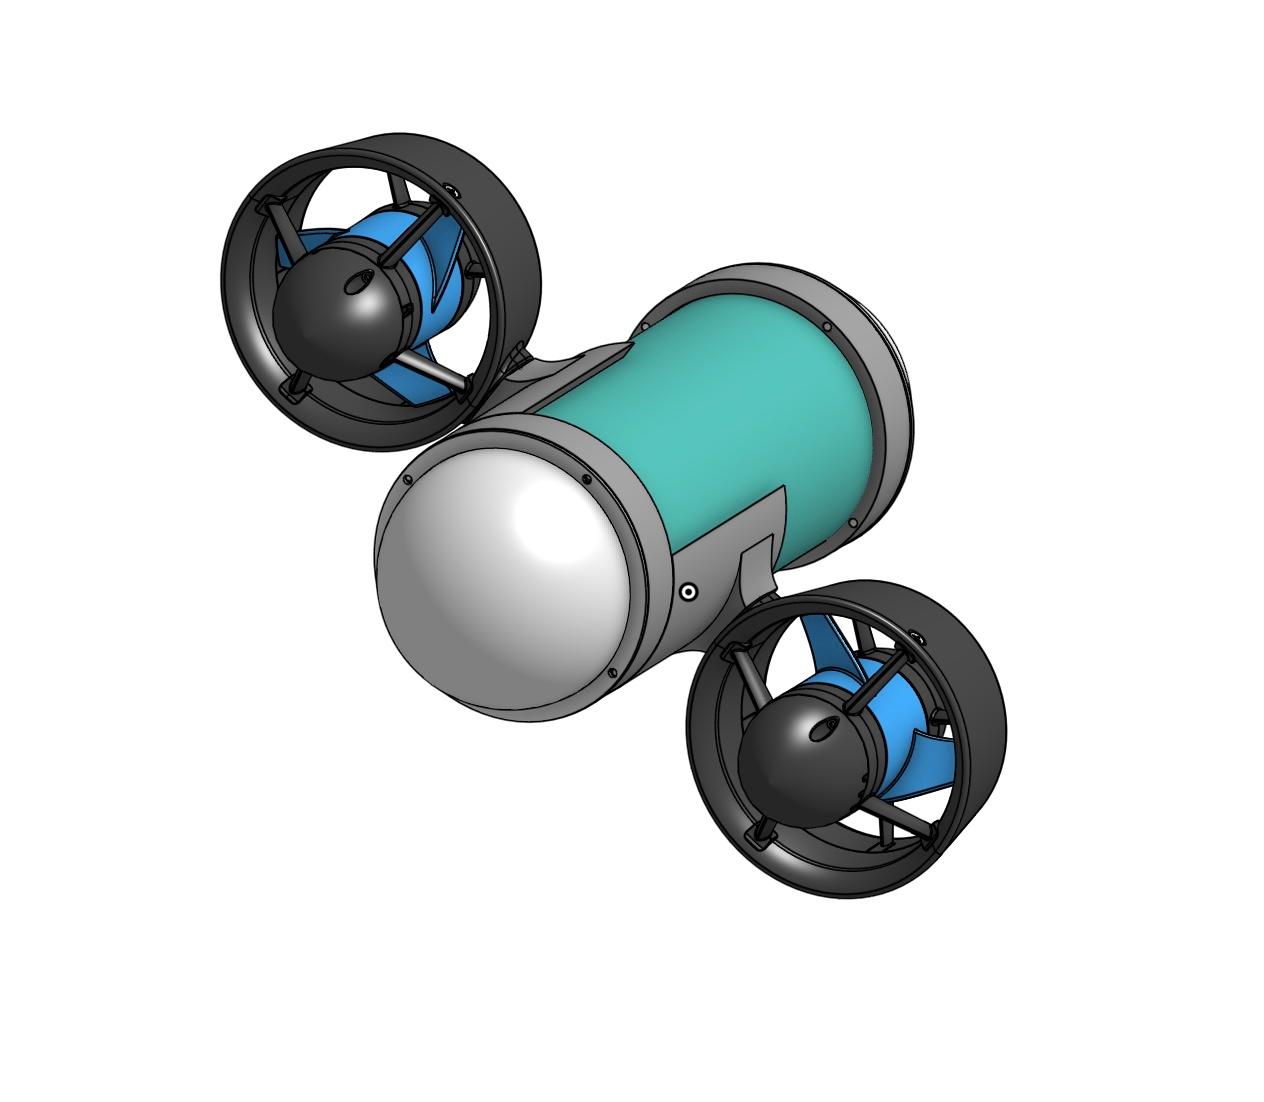
  • CAD model of an ROV with a cylindrical hull, clear front dome and two ducted thrustersROVCAD/modeling project · Primarily visual/CAD work
05 — Contact

Let’s build something useful.

I’m interested in robotics, AI, embedded systems, and physical engineering work that creates real utility. If you’re working on something in that space, I’d like to hear about it.